 01Space
Embedded Satellite Software
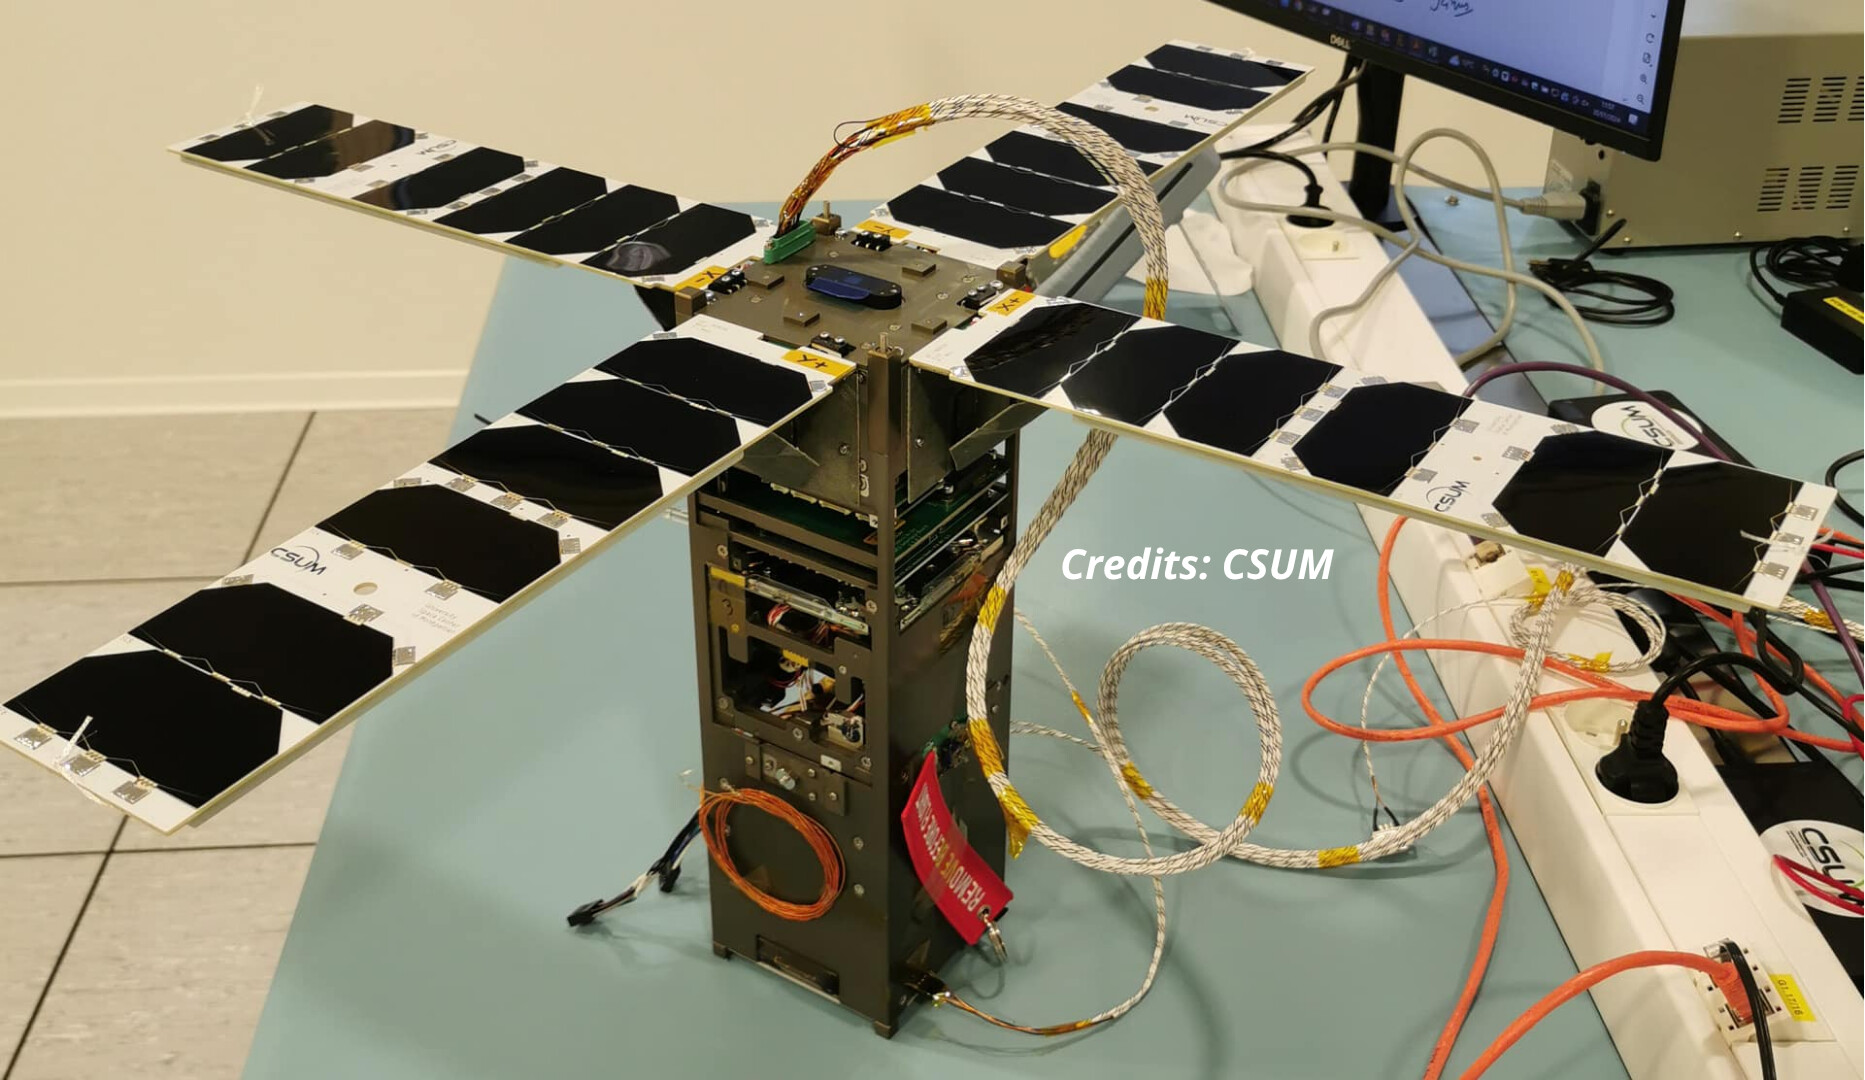
Flight software, low-level drivers and validation tooling for 1U, 3U and 12U nanosatellite platforms.
Work spanning requirements, implementation, debugging, verification and documentation.
Embedded systems engineer working across flight software, autonomous robotics and hardware integration, from nanosatellites to quadruped robots.
A selection of professional and personal systems where software meets real hardware.
01SpaceFlight software, low-level drivers and validation tooling for 1U, 3U and 12U nanosatellite platforms.
Work spanning requirements, implementation, debugging, verification and documentation.
 02Space
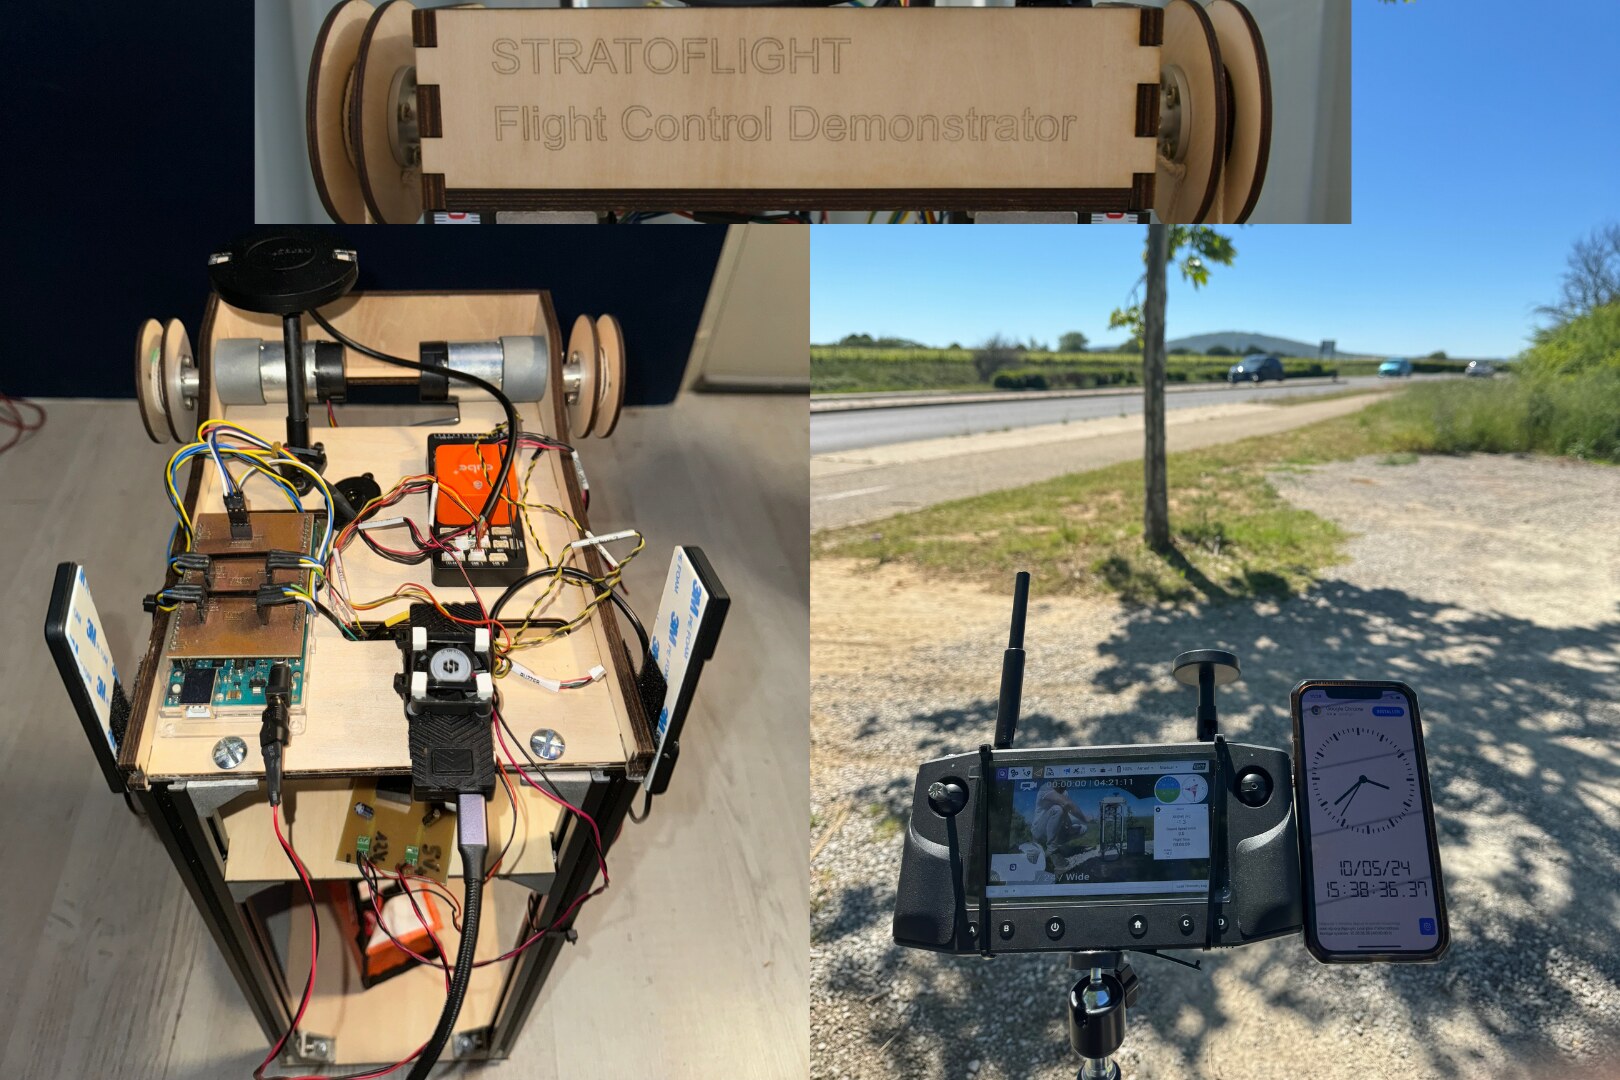
Designed and built a remotely operated parachute-control demonstrator for a stratospheric spacecraft, from system requirements and component selection through full prototype integration.
Validated end-to-end remote control during an 11 km field test.
Profiled and optimized an attitude-control implementation, then ported it to custom embedded hardware.
Identified performance bottlenecks and validated improvements on the target.
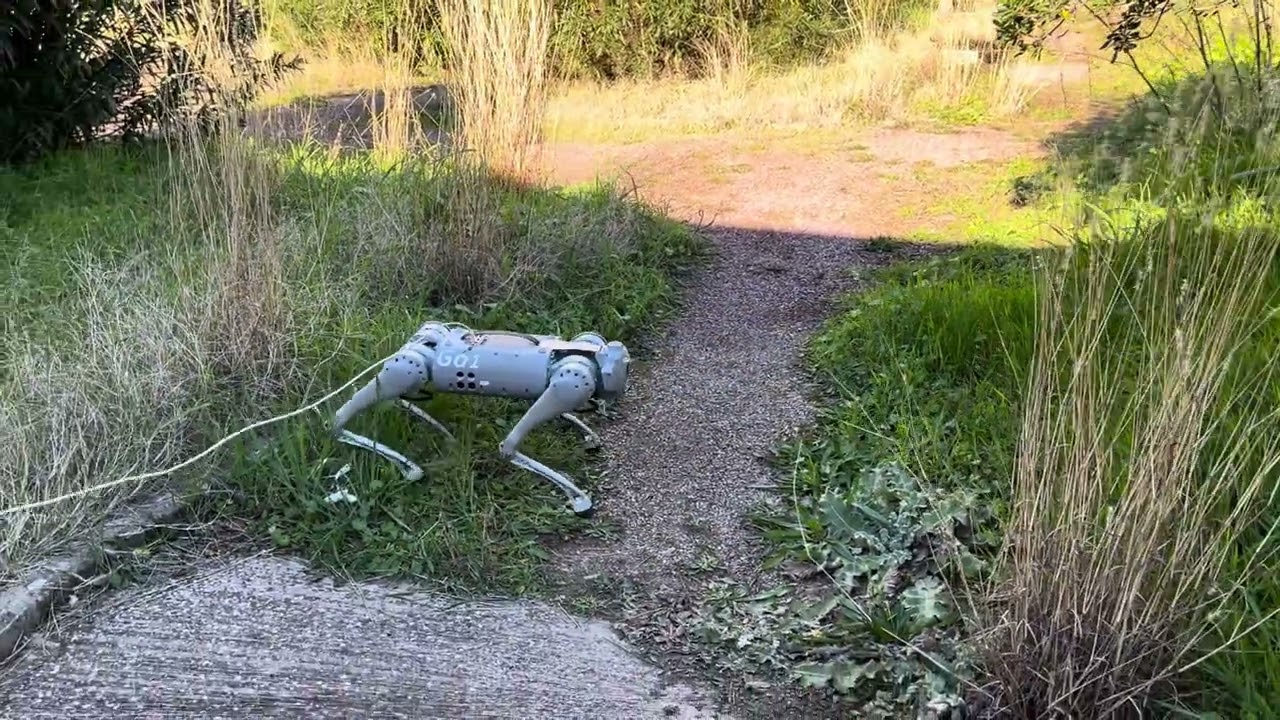
Adapted a locomotion stack for a quadruped robot and brought it from simulation to real-world testing.
Implemented and validated gait-control functionality on physical hardware.
Automated the tether management system linking an ROV to an ASV using underwater positioning and a ROS 2 control stack developed in C++.
Developed and analysed the control logic in Python and Matplotlib simulation, then validated it on hardware in a test pool.
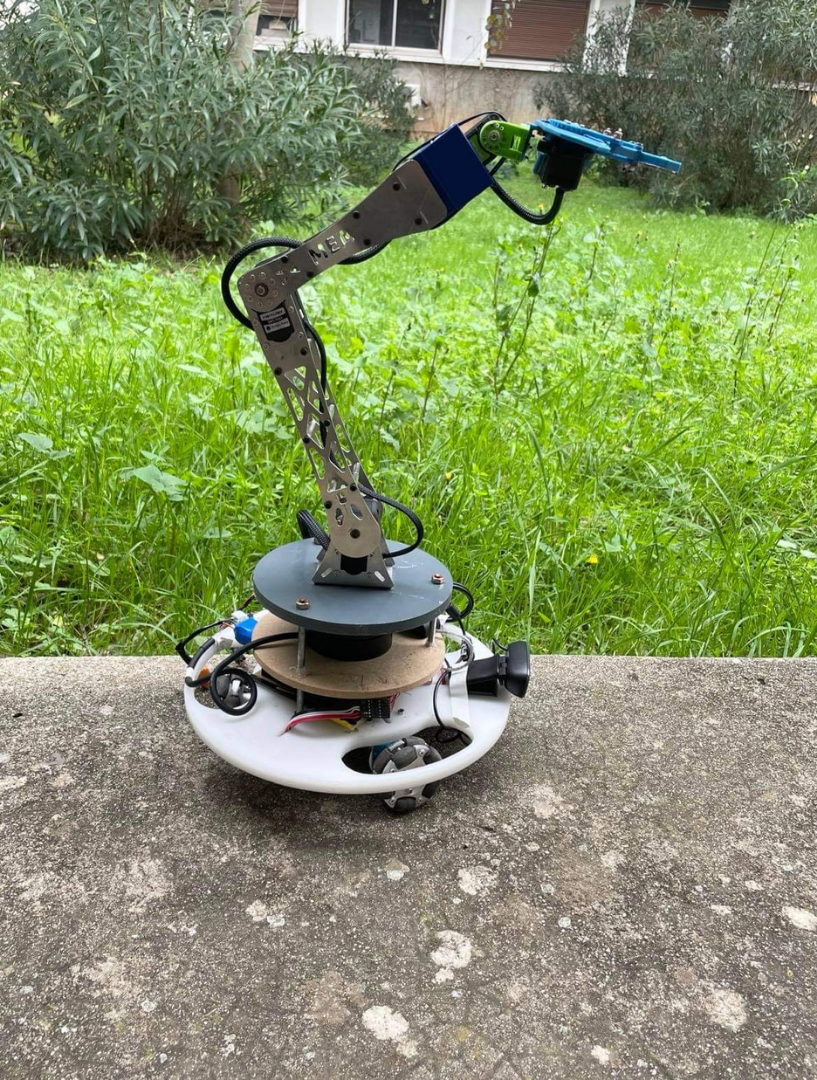
Led development of a Linux-based robot integrating an arm, camera and LiDAR.
Built remote and motor control plus automated object detection and pickup.
 07Personal
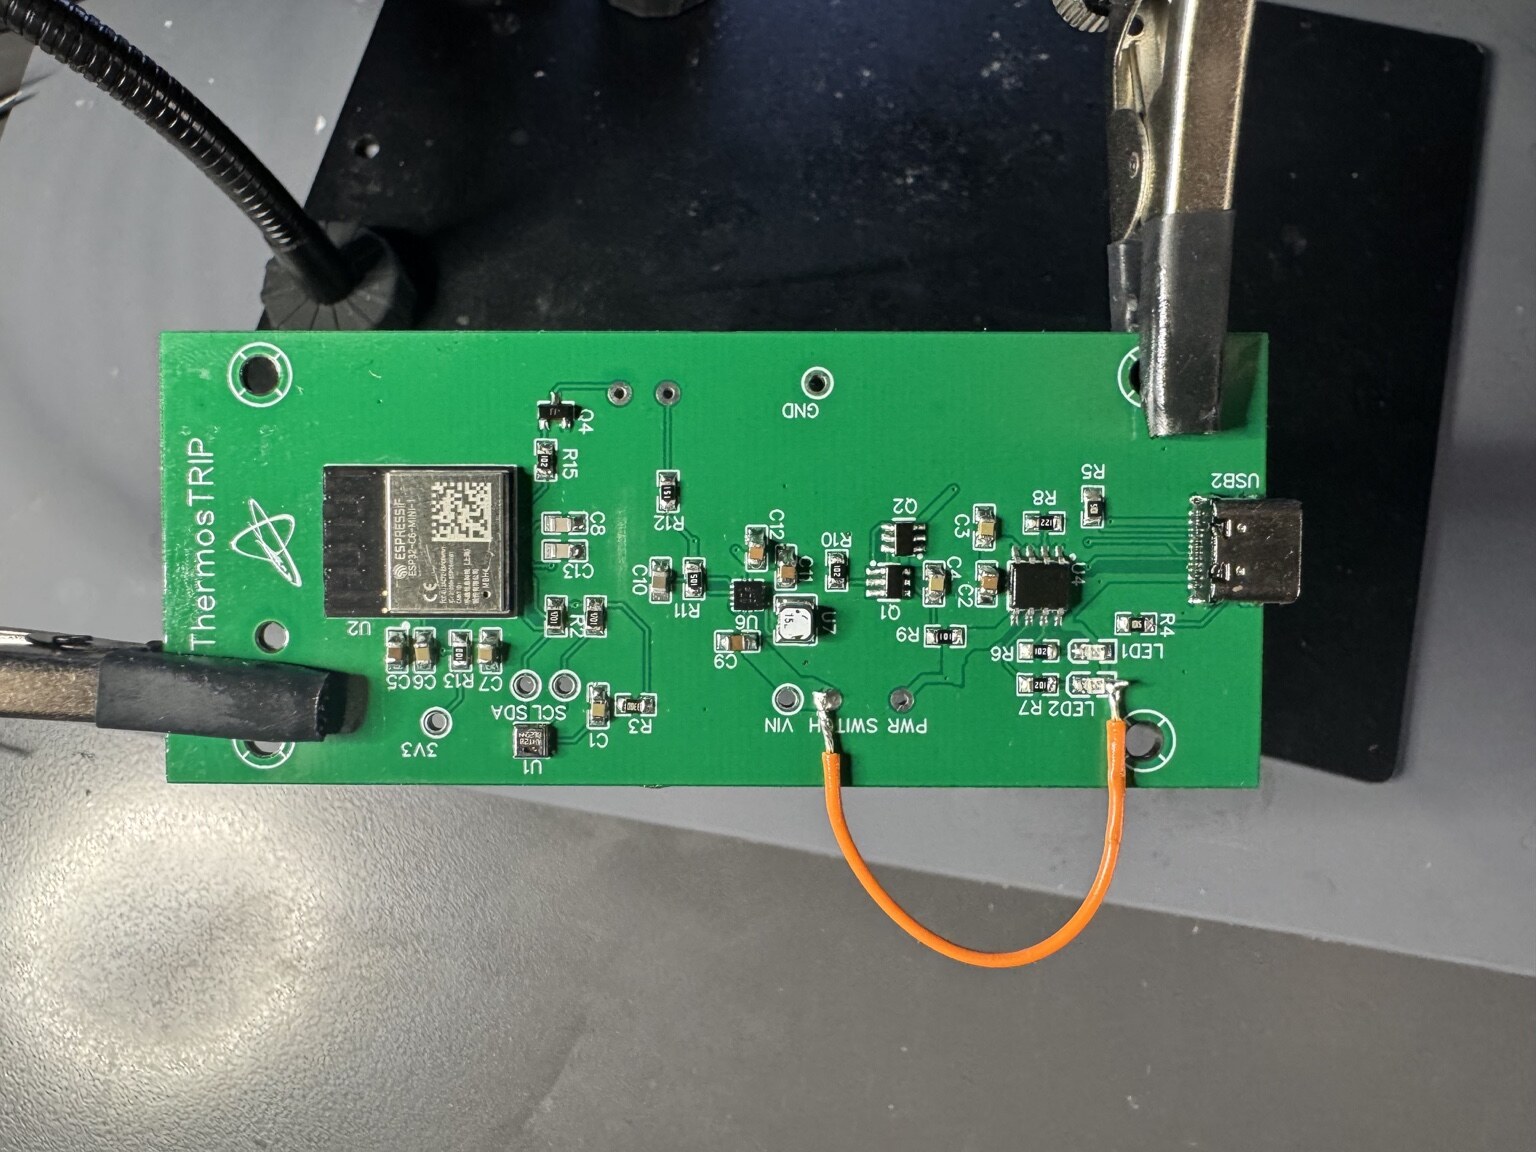
Designed and built a custom PCB for a connected thermostat made to solve a practical winter problem.
A full personal build spanning electronics, embedded systems and prototyping.
 08Industry
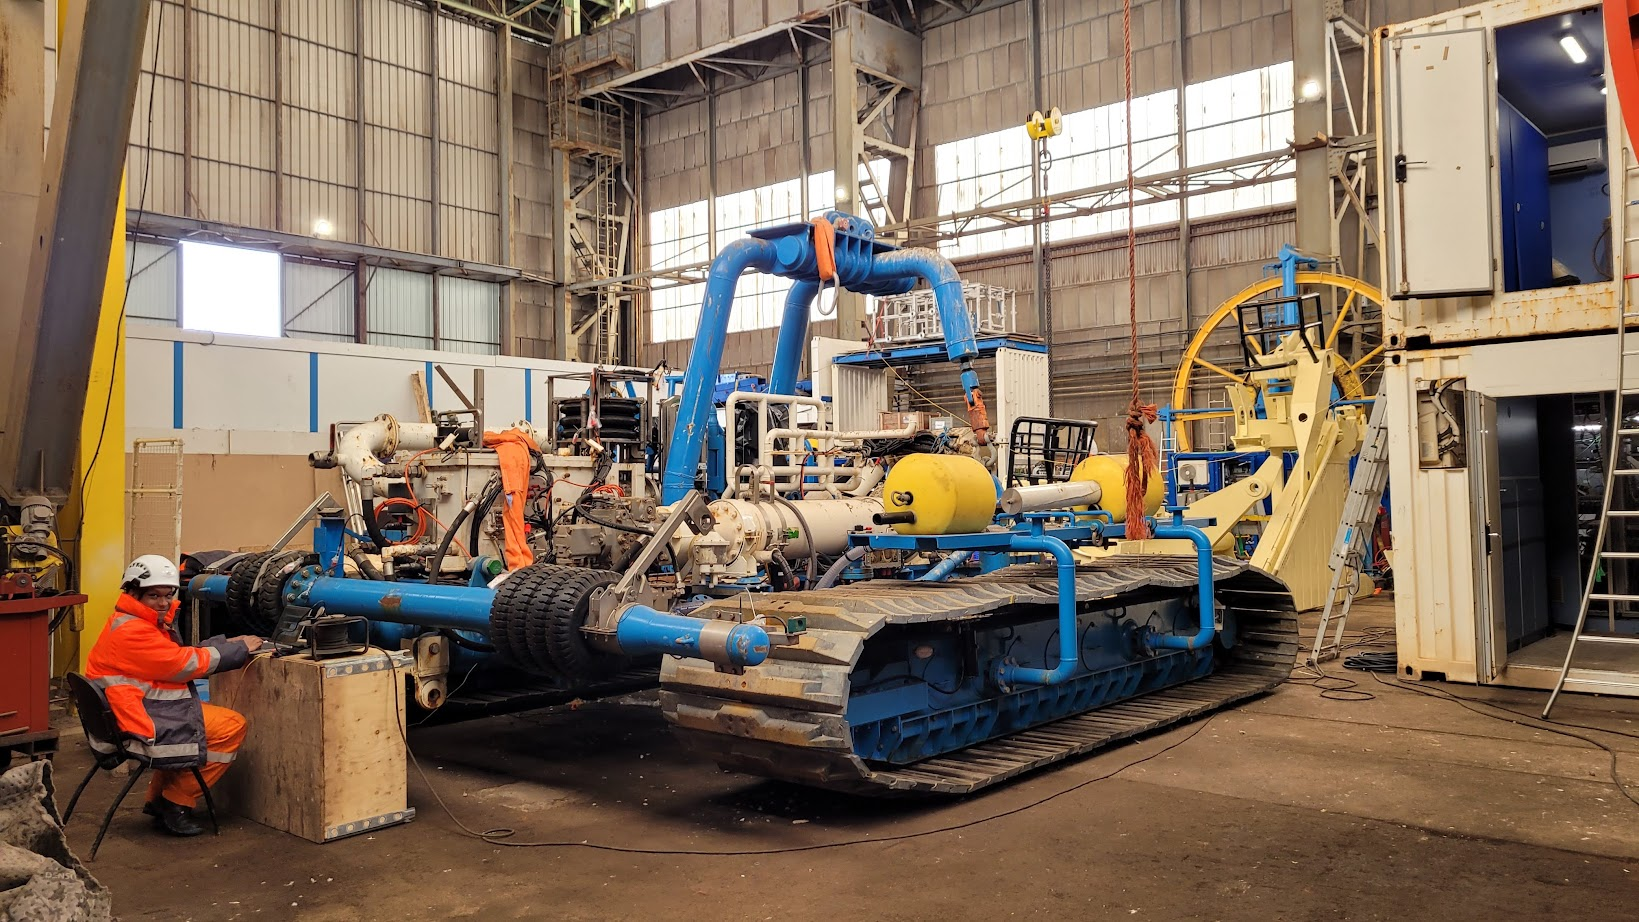
Upgraded the control system and designed the operator interface for an industrial subsea machine.
Integrated, tested and validated the system directly on the machine before FAT.
Professional work on mission-critical embedded systems, control and validation.
Centre Spatial de l’Université de Montpellier
Flight software, drivers, ADCS optimization, Python/Docker test infrastructure, integration and satellite operations.
Stratoflight
System architecture and requirements for a remotely operated stratospheric system and parachute-control subsystem.
LD Travocean
Control-system upgrade, HMI development and on-machine validation for a 27-ton subsea trencher.
C · C++ · Python
Embedded Linux · Git
Docker · Testing
MSP430 · PIC18F
STM32 · TMS570
CAN · I²C · UART
ROS 2 · Control
ADCS / AOCS · RF
V&V · Integration
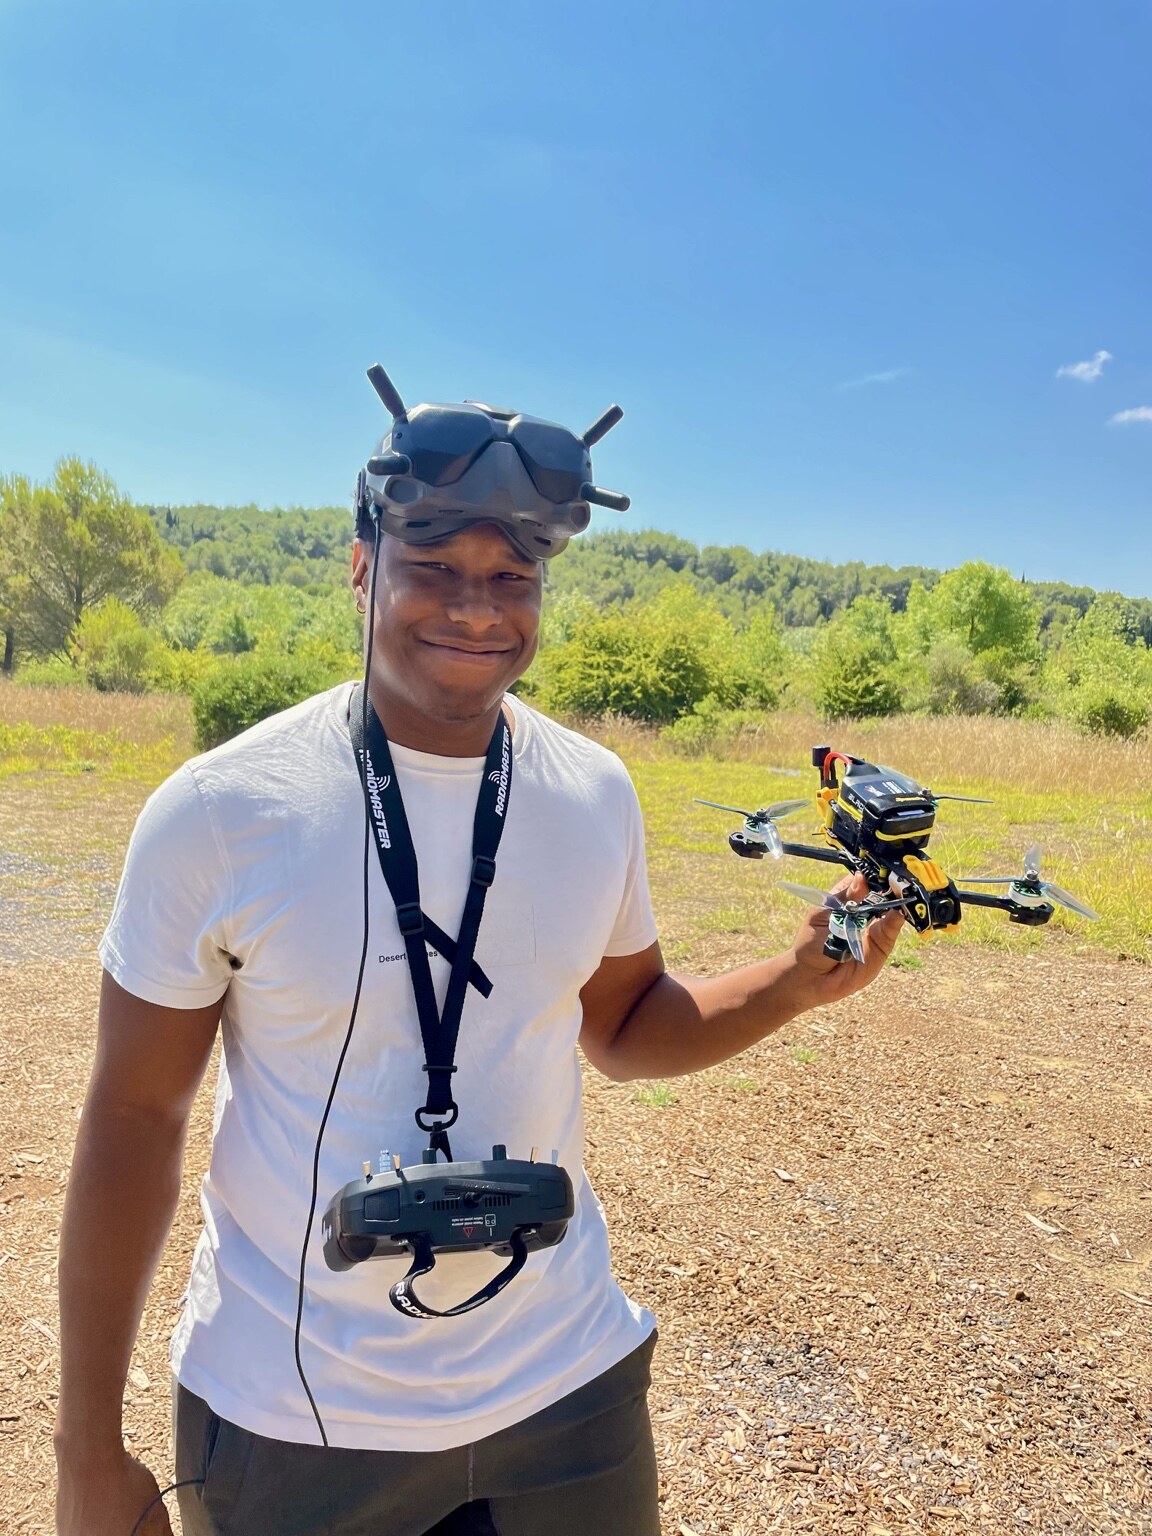
I enjoy taking ideas all the way to working physical systems. Outside work, that means designing electronics, building FPV drones, printing custom parts and making things simply because they should exist.
 04
 05